Oct 2021 · Sensor Calibration / Self-supervised / Camera-LiDAR / IROS 2021 / 10,000x Speedup
SemAlign: Sensor Calibration in Under a Second
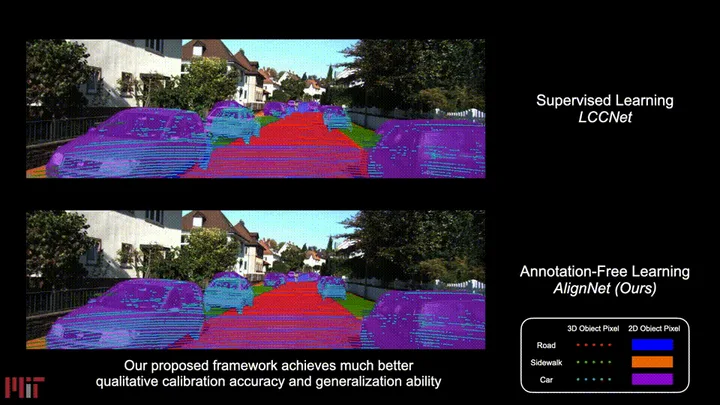
A co-first-authored camera–LiDAR calibration framework published at IROS 2021. Self-supervised semantic alignment removes the need for manual labels and reduces calibration from more than three hours to under one second.
The challenge
Camera–LiDAR calibration aligns different observations of the same scene. The existing workflow took more than three hours, making repeated calibration costly.
The approach
SemAlign uses self-supervised semantic alignment to perform calibration without manual labels, connecting scene understanding with geometric sensor alignment.
The outcome
Calibration time was reduced to under one second. Published at IROS 2021; the paper and demonstration are linked below.