Jul 2020 · Computer Vision / YOLOv3 / 200ms Full-stack Latency / Stereo Vision / IROS 2020
High-Speed Autonomous Racing: 200ms Full-Stack Vision
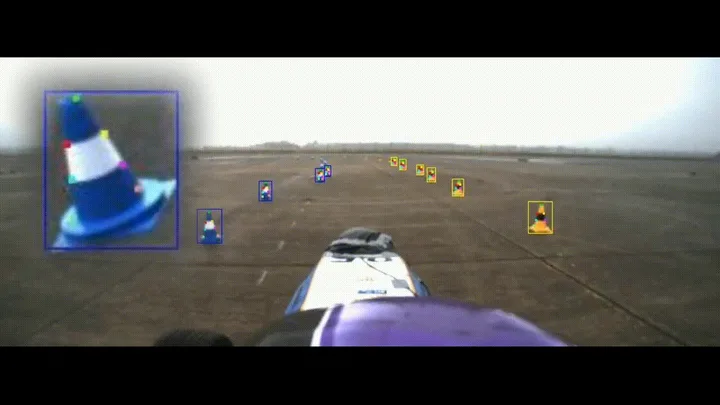
A vision pipeline for autonomous racing, published at IROS 2020. Optimized YOLOv3 detection, keypoint pose estimation and sub-microsecond stereo synchronization operate within a 200ms full-stack latency budget.
The challenge
At racing speeds, detection, geometric estimation and camera synchronization must fit within one end-to-end latency budget.
The approach
Optimized YOLOv3 detection, custom keypoint pose estimation and sub-microsecond stereo camera synchronization form the perception pipeline.
The outcome
A 200ms full-stack latency budget. Published at IROS 2020, with code, video and a training tutorial available below.