May 2021 · End-to-End Learning / Sparse Convolution / LiDAR / ICRA 2021 / Full-scale Vehicle
LiDAR End-to-End Navigation: Full-Scale Vehicle Deployment
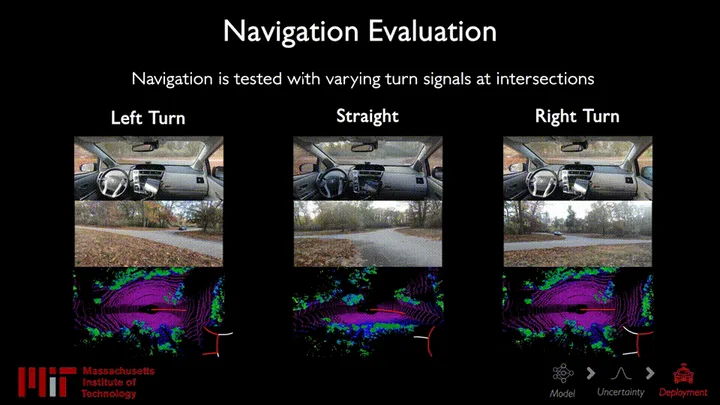
An end-to-end LiDAR navigation framework published at ICRA 2021. Sparse convolution and hardware-aware architecture design connect raw point clouds to steering commands, with deployment on a full-scale autonomous vehicle.
The challenge
End-to-end LiDAR navigation must connect high-dimensional point clouds to vehicle control within the constraints of a full-scale vehicle.
The approach
Sparse convolution optimization and hardware-aware architecture design map raw point-cloud input to steering commands.
The outcome
Demonstrated on a full-scale autonomous vehicle and published at ICRA 2021. The paper and video document the method and deployment.